
柯灿
通讯员:卫周瑶 来源:微电子学院 阅读: 发布时间:2026-09-16 审稿:古江波
柯灿
Ø 个人简介
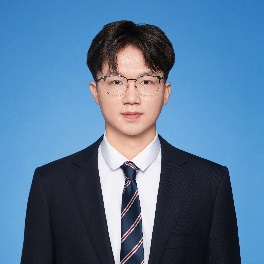
柯灿,博士,武汉纺织大学微电子学院讲师,华中科技大学与武汉纺织大学联合培养博士后。主要从事无人系统智能控制的研究。以第一作者在相关领域主流SCI期刊IEEE Transactions on Cybernetics、Ocean Engineering、International Journal of Robust and Nonlinear Control等发表研究论文多篇,其中SCI论文6篇,EI论文1篇,中国科技核心期刊1篇。主持一项市级科研项目,多次参与国家自然科学基金项目。
办公地点:4-102B
电子邮箱:20268016@wtu.edu.cn
Ø 教育经历
2014.09-2018.06 湖北师范大学 电气与自动化学院 大学本科
2018.09-2021.06 西南大学 电子信息工程学院 硕士研究生
2021.09-2026.03 浙江大学 信息与电子工程学院 博士研究生
Ø 工作经历
20026.6-至今 武汉纺织大学微电子学院 讲师,博士后
Ø 研究方向
无人系统智能控制与优化,电路设计
Ø 代表性成果
1. Can. Ke, Huifang Chen and Lei Xie. Cooperative formation control for the air-sea heterogeneous unmanned system under adaptive switching topology [J]. International Journal of Robust and Nonlinear Control, 2025, 35(13), 5402-5419.
2. Can Ke, Chuandong Li and Le You. Consensus of nonlinear multiagent systems with grouping via state-constraint impulsive protocols[J]. IEEE Transactions on Cybernetics, 2021, 51(8): 4162-4172.
3. Can. Ke, Huifang Chen. Cooperative path planning for air–sea heterogeneous unmanned vehicles using search-and-tracking mission[J]. Ocean Engineering, 2022, 262: 112020.
4. Can. Ke, Chuandong Li and Qiangqiang Zhang. Distributed adaptive fault-tolerant consensus of nonlinear multi-agent systems via state-constraint impulsive protocols with time-delay[J]. IEEE Transactions on Network Science and Engineering, 2020, 7(4): 3112-3121.
5. Can. Ke, Huifang Chen and Lei Xie. Cross-domain fixed-time formation control for an air-sea heterogeneous unmanned system with disturbances[J]. Journal of Marine Science and Engineering, 2023, 11(7): 1336.
6. Can. Ke, Chuandong Li, Yiyan Han, et al. Adaptive fuzzy leader-following consensus for nonlinear multi-agent systems via state-constraint impulsive control[J]. International Journal of Machine Learning and Cybernetics, 2021, 12(10): 3011-3022.